Senior Undergraduate Student at Michigan State University
lehoang2@msu.edu
Hi! I am Hoang Le, a Computer Science undergraduate at Michigan State University (MSU). I am advised by Dr. Zijun Cui at the Domino Lab (MSU), and I also work with Dr. Xingxing Zuo at the RCL Lab (MBZUAI) through the UGRIP program. Previously, I worked with Dr. Abhinav Kumar and Dr. Xiaoming Liu at the MSU CV Lab.
My research interests span Physical AI, Robotics, and 3D Perception. I am always open to collaboration opportunities, so please feel free to reach out!
Awards
Engineering Summer Undergraduate Research Fellowship, Michigan State University, 2024
Professorial Assistantship, Michigan State University, 2023–2025
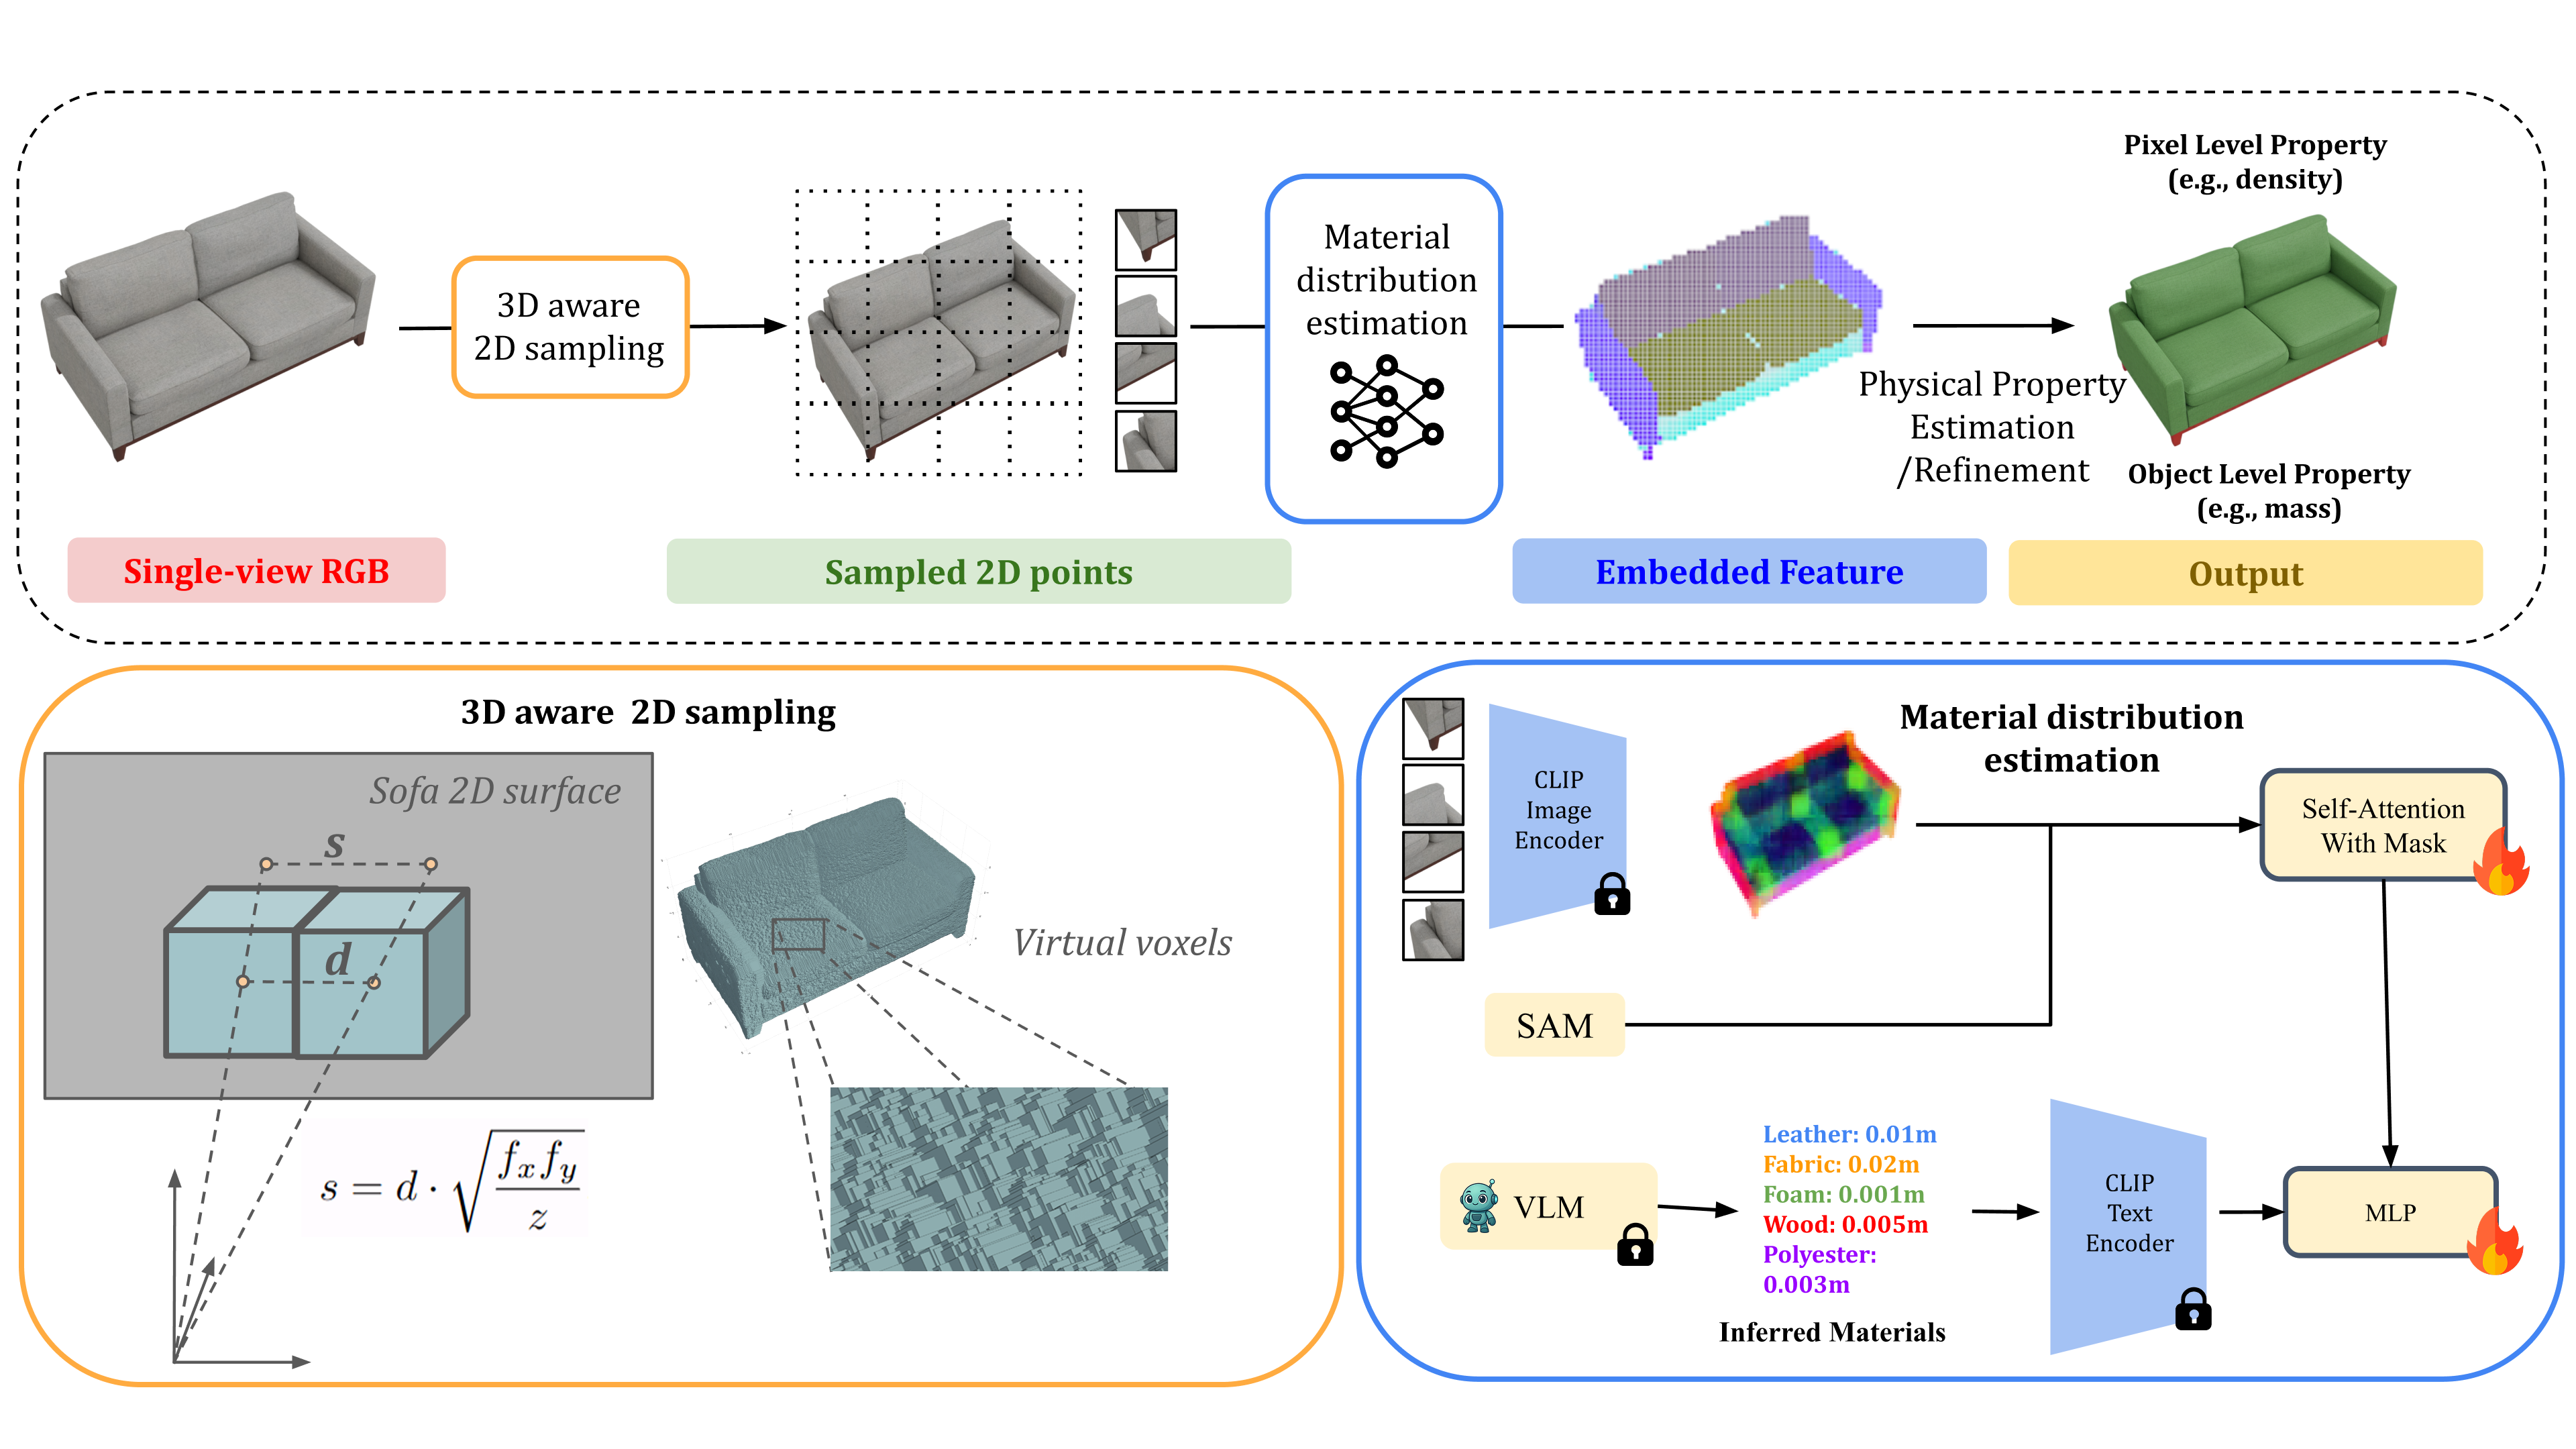
Inferring physical properties such as mass, stiffness, and elasticity from a single image is essential for simulation and embodied AI, yet most existing approaches rely on multi-view reconstruction or physics-based supervision. We introduce SiPhy, a unified framework for single-image physical property reasoning that aligns 3D-aware visual cues, depth with language-based material knowledge. From one RGB image, SiPhy samples pseudo-voxel points, extracts CLIP features, and grounds them to material candidates proposed by an VLM. A part-based contrastive aggregator enforces region consistency, while a heaviness-aware refinement improves thickness and volume estimation for dense objects. Across ABO-500, MVImgNet-100, and PhysXNet-100, SiPhy achieves state-of-the-art single-image performance, surpassing multi-view reconstruction methods by improving mass MnRE by up to 93% (vs. PUGS), reducing density MAE by 35.5% (vs. NeRF2Physics), and lowering Young’s modulus error by 23.5%. We further validate SiPhy on real hand-object interaction datasets, demonstrating its potential as a data annotation engine for physical understanding from single-view imagery.
@inproceedings{le2026siphy,title={SiPhy: Single-Image Physical Property Reasoning},author={Le, Hoang and Kwon, Joonwoo and Ismayilzada, Elkhan and Zhang, Yufei and Cui, Zijun},booktitle={Proceedings of the European Conference on Computer Vision (ECCV)},year={2026},note={Main track. arXiv and ECCV links coming soon.},}
in progress
FunctionalGrasp: Part-Aware Functional Maps for Cross-Category Generalizable Robotic Grasping from a Single Demonstration
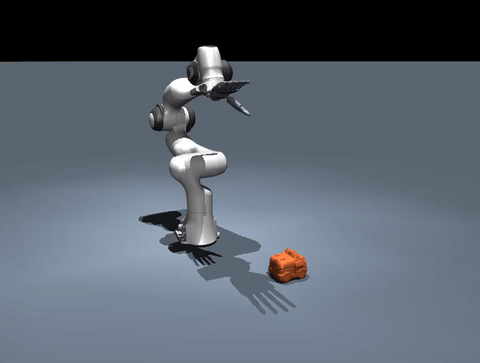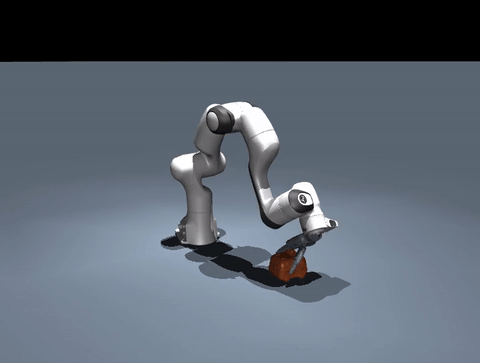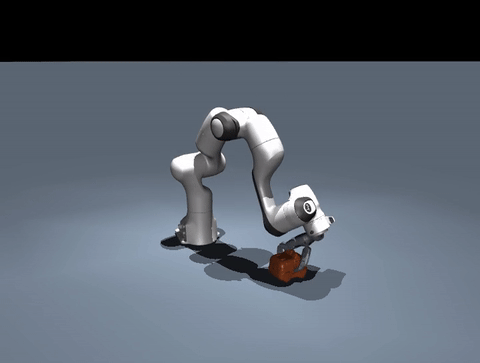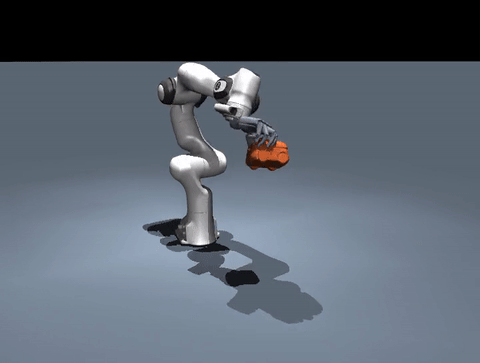
Exploring how to transfer a single human grasp demonstration to a robotic dexterous hand across object categories using part-aware functional correspondences. The goal is to enable generalizable, contact-rich robotic grasping from just one demonstration.
@unpublished{le2026functionalgrasp,title={FunctionalGrasp: Part-Aware Functional Maps for Cross-Category Generalizable Robotic Grasping from a Single Demonstration},author={},year={2026},note={Ongoing work at UGRIP.},}
You can even add a little note about which of these is the best way to reach you.